
About Me
Hi! I am Jiazhou Zhou (周佳舟), a PhD student (2024.09–) at AI Thrust, Information Hub of The Hong Kong University of Science and Technology (Guangzhou). I am fortunate to be advised by Prof. Lei Zhang and Prof. Yingcong Chen. I am also a research intern at International Digital Economy Academy (IDEA).
Research Interests
Dedicated to building Next-Generation Self-Evolving Embodied Cognitive Systems grounded in physical reality. My research establishes a closed loop of Physical Interaction — World Modeling — Policy Self-Evolution to transcend static pre-training paradigms, focusing on three core thrusts:
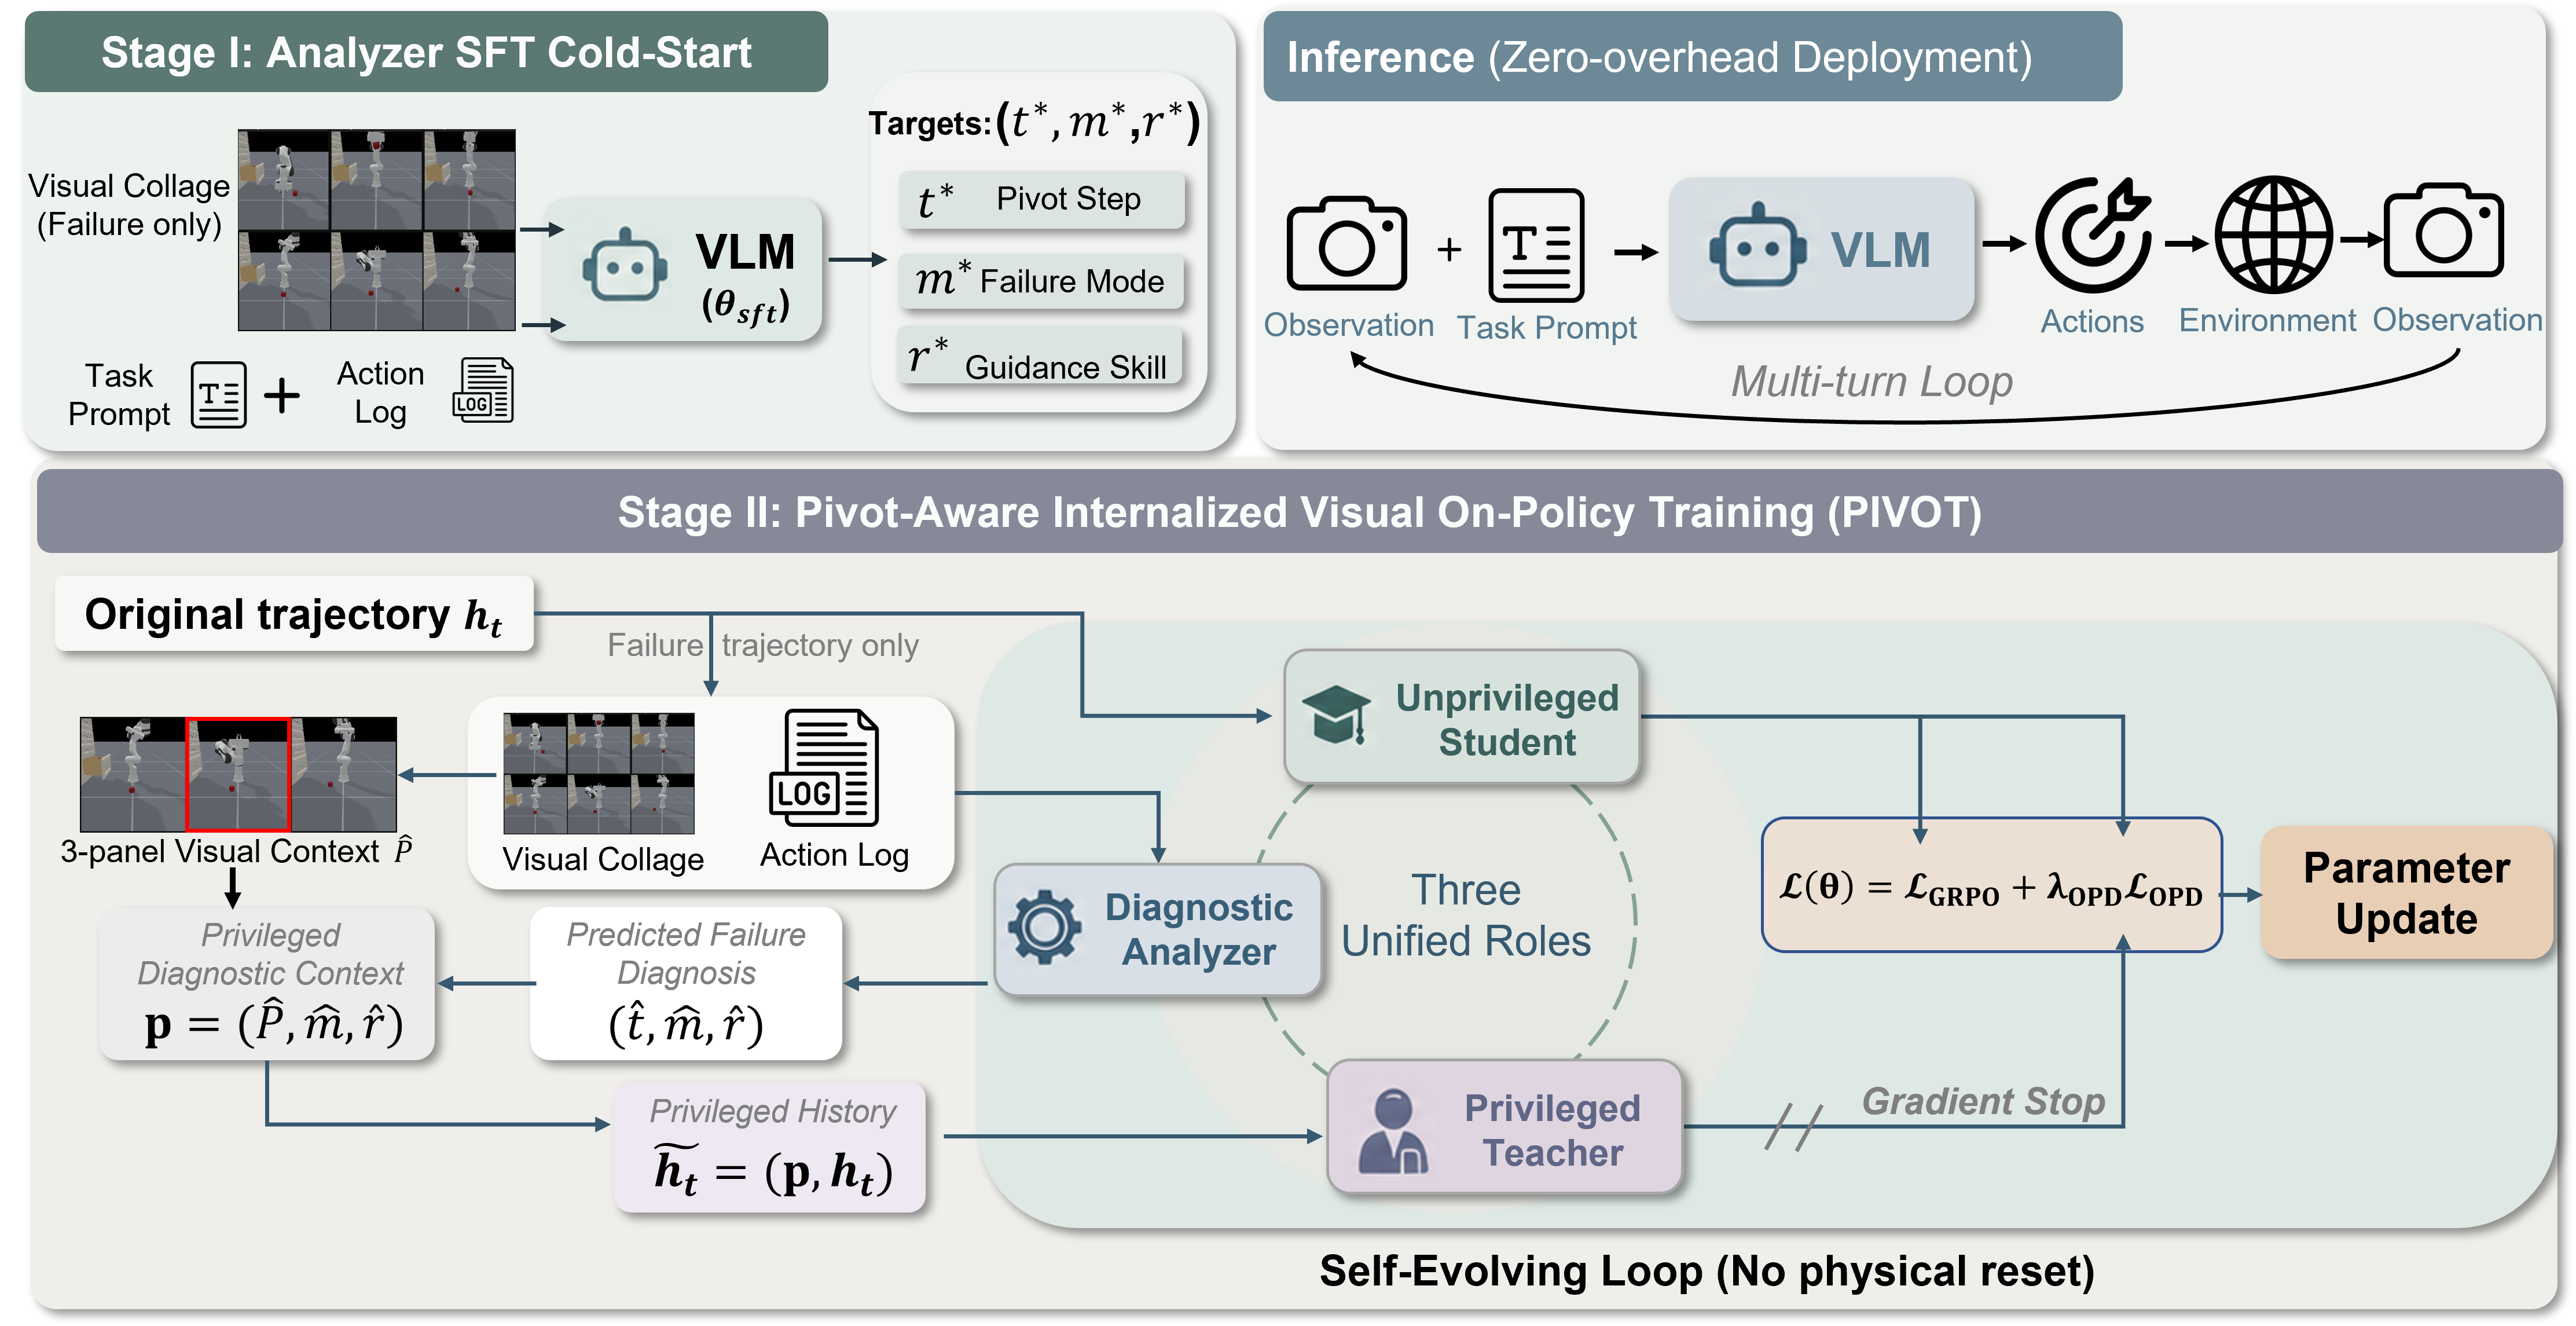
Investigating active intervention and long-horizon multi-turn planning for embodied agents. Specifically, addressing long-term temporal credit assignment under sparse rewards via on-policy self-distillation and multimodal agentic reinforcement learning, enabling continuous self-improvement without dense human supervision.
Developing physics-grounded world models that serve as internal neural physics engines for embodied agents. Leveraging active interrogation and self-reflection to facilitate latent counterfactual imagination, spatiotemporal causal prediction, and test-time planning scaling to provide predictive priors for complex decision-making.
Designing modality-agnostic representations across vision, touch, 3D geometric priors, and neuromorphic event streams in dynamic, unstructured physical environments, establishing a low-latency, robust sensory foundation for embodied physical grounding.
Publications (Selected)
Selected publications (12 papers, 10 published/accepted). Please refer to my Google Scholar for a full paper list.
-
 Preprint
Under review, 2026.
-
 Preprint
-
 EMNLP 2026
The 2026 Conference on Empirical Methods in Natural Language Processing, EMNLP, 2026.
-
 CVPR 2024 Highlight
The IEEE/CVF Conference on Computer Vision and Pattern Recognition, CVPR (CCF-A), 2024. Highlight (2.8%)
-
 AAAI 2025
The 40th Annual AAAI Conference on Artificial Intelligence, AAAI (CCF-A), 2025.
-
 NeurIPS 2025
The Thirty-Ninth Annual Conference on Neural Information Processing Systems, NeurIPS (CCF-A), 2025.
-
 CVPR 2024
The IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR) (CCF-A), 2024.
-
 NeurIPS 2024
The Thirty-Eighth Annual Conference on Neural Information Processing Systems, NeurIPS (CCF-A), 2024.
-
 ECCV 2024
European Conference on Computer Vision, ECCV (CCF-B), 2024.
-
 ECCV 2024
European Conference on Computer Vision, ECCV (CCF-B), 2024.
Professional & Academic Experience
- [2025.08 - Present]: Research Intern, CVR Group, International Digital Economy Academy (IDEA)
- [2023.06 - 2024.09]: Research Assistant, VLIS Lab, The Hong Kong University of Science and Technology
- Supervisor: Addison, WANG Lin
Services
- Reviewer:
- Conferences: ICLR, CVPR, ECCV, ICCV, NeurIPS, AAAI, COLM, WACV, BMCV
- Journals: IEEE Transactions on Neural Networks and Learning Systems (TNNLS), IEEE Transactions on Intelligent Transportation Systems (TITS)
- Teaching Assistant:
- UFUG2102, Matrix Algebra and Applications, HKUST(GZ), 2025.6-2025.7
- CMAA6102, Computational Media and Arts Program Seminar, HKUST(GZ), 2024.9-2025.5